Incidents in European waters have focused attention on the risk. Deliberate interference is only part of the picture. Anchoring, fishing activity, equipment failure, and natural events also damage subsea assets. For an operator or naval command, the first challenge is uncertainty: what happened, whether it was accidental, whether other assets are exposed and how quickly a response is needed.
That uncertainty reveals the limits of conventional maritime surveillance. Frigates, patrol aircraft, and crewed survey vessels provide capable coverage, but cannot be everywhere or stay on station. Assigning high-value platforms to watch dispersed infrastructure is expensive and leaves gaps. Uncrewed systems can close them, not by replacing ships and aircraft, but by directing them towards areas requiring attention.
A System-to-System Approach
At Cellula Robotics, we describe the operational model as “Detect. Inspect. Protect.” It is a system-of-systems approach rather than a single vehicle or sensor presented as the answer.
Detection begins with persistent coverage that establishes normal activity. Seabed sensor nodes can listen around priority infrastructure and pass alerts through an acoustic network. Surface vessels, satellites, patrol aircraft, and shore-based systems add context, including vessel movements and known operations. None offers a complete picture alone. Together, they help operators decide whether an event is routine or requires investigation.
Inspection turns an alert into usable evidence. Autonomous underwater vehicles (AUVs) can survey cable routes, pipelines, foundations and other assets, producing repeatable condition records. Regular missions create the baseline required for change detection. When a sensor reports unusual activity, or the surface picture identifies a vessel of concern, an AUV can inspect the area without waiting for a specialist ship and crew to mobilize.
The choice of vehicle should follow the mission. Compact systems can launch from ports or vessels of opportunity for local work.
Long-endurance AUVs can cover extended routes and remain deployed for days or weeks. Payload-capable vehicles can deliver sensors or communications equipment, while hovering systems suit close inspection around complex structures. A mixed fleet gives commanders options without forcing one platform into every role.
Underwater communications remain a practical constraint. Bandwidth is limited, latency is unavoidable and continuous contact cannot be assumed. An effective architecture must decide what is transmitted immediately, processed on the vehicle or held until recovery. Low-latency acoustic alerts may cue another asset, while detailed imagery and survey data can be reviewed later. Designing around these realities is more useful than treating the underwater domain like a terrestrial network.
Protection still requires people and authority. Uncrewed systems can collect evidence, maintain surveillance, and shorten the time between alert and inspection. Decisions with legal, diplomatic, or military consequences remain with commanders and governments. Crewed ships and aircraft bring communications, endurance, and the ability to intervene. They are more effective when they arrive with recent imagery, sensor records, and a documented pattern of activity rather than an unverified report.
Towards Operational Adoption
NATO’s Baltic Sentry and the experimentation conducted through Task Force X-Baltic show how this model is beginning to move from trials towards operational adoption. Baltic Sentry combines conventional maritime forces with enhanced surveillance, while Task Force X-Baltic has tested how air, surface and underwater uncrewed systems can contribute to persistent awareness and the protection of critical underwater infrastructure. The value lies in connecting commercial technology, military platforms, and shared operational data within one mission.
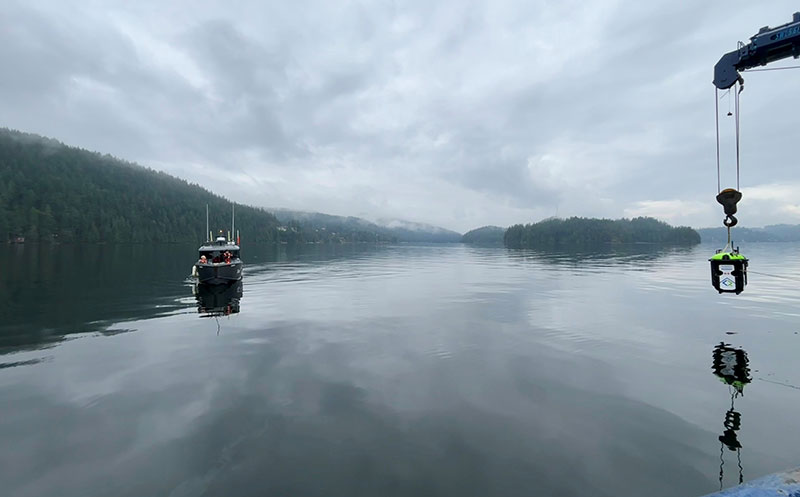
Commercially developed systems have a valuable role because offshore survey, environmental monitoring, and science have advanced subsea navigation, sensing, autonomy, and launch-and-recovery methods. Proven commercial off-the-shelf platforms can shorten the path from requirement to deployment. Modular payloads let operators add sensors or mission equipment without replacing the vehicle. Bespoke defense systems remain necessary for some tasks, but routine monitoring should not automatically demand one.
Integration Challenges
Integration may be the harder problem. Vehicle endurance and sensor range are easy to compare; the ability to work within an existing command environment is less visible. Data must be accessible, time-stamped and understandable to different operators. Interfaces should allow new sensors and vehicles without rebuilding the architecture. Support requirements also matter. A system dependent on a large specialist team may be difficult to sustain across multiple ports and operating areas.
Geography changes the requirement. A cable landing point needs different coverage from a long route across deep water. Offshore wind farms combine cables, foundations and substations. Pipelines and interconnectors may cross several jurisdictions, each with different authorities and reporting. Protection plans need concentrated surveillance around priority sites, supported by mobile systems able to investigate across a wider region.
Practical Resilience
No architecture can guarantee that damage will not occur. Resilience comes from finding incidents quickly, understanding their cause, limiting disruption and supporting repair. The objective is not to guard every meter of infrastructure with a naval asset. It is to create enough awareness and response capacity that suspicious activity is detected, investigated and attributed before an adversary can act with confidence.
Critical underwater infrastructure protection is becoming a standing maritime task. Naval forces will continue to provide command, deterrence and response, but persistent coverage will depend on a broader mix of technology, commercial operators and government partners. The practical task now is to connect seabed sensing, autonomous inspection, surface surveillance and crewed intervention into an operating capability that can be deployed routinely, not only after the next cable or pipeline is damaged.