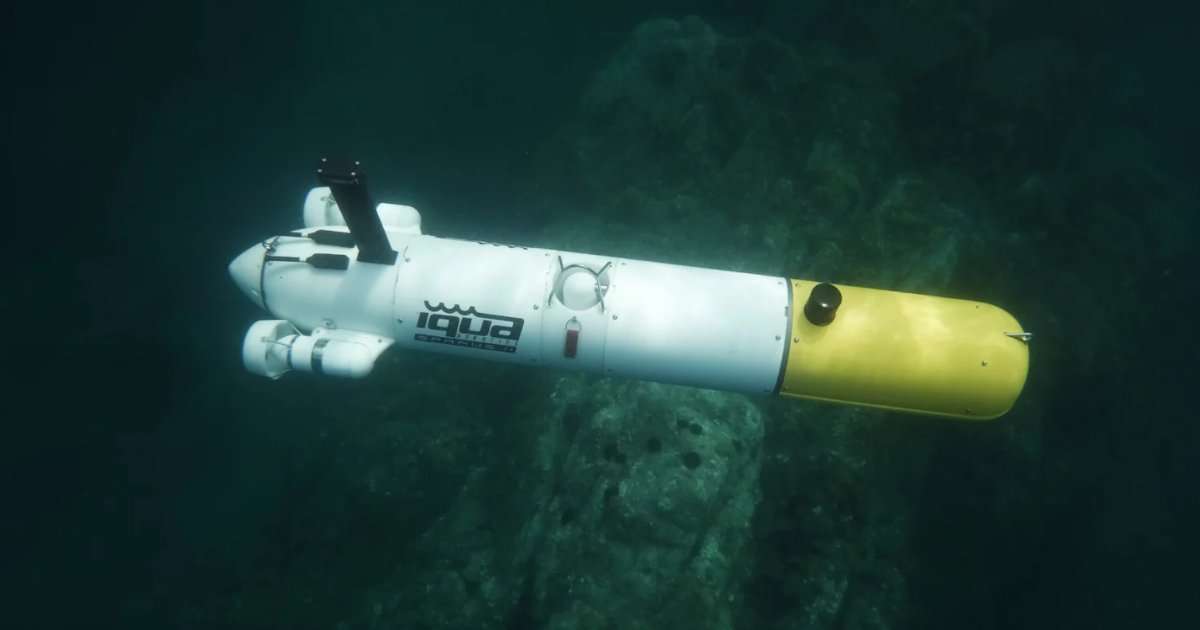
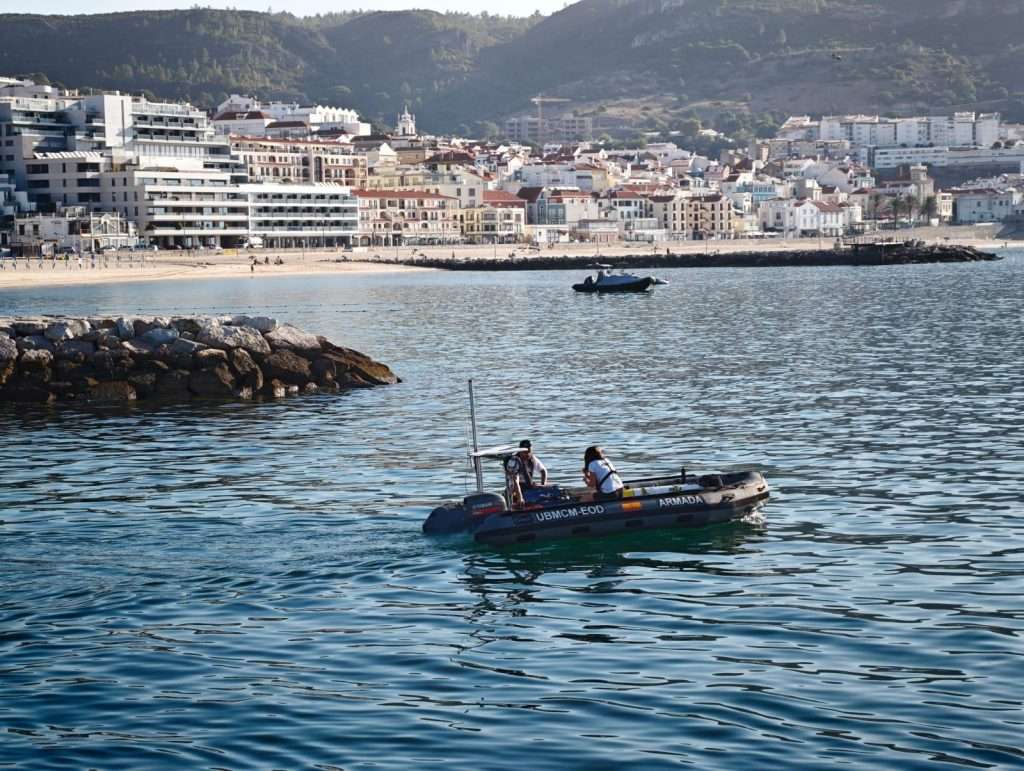
From September 3–24, 2026, the IQUA Robotics team was based in Sesimbra, Portugal, working alongside the Spanish Navy’s Mine Countermeasures (MCM) group. Over the exercise, the company’s SPARUS II AUV ran 16 different MCM serials, detecting many potential contacts and confirming the presence of multiple mines. For the first time, IQUA also worked with the Rapid Environmental Assessment (REA) group and took part in the exercise’s tactical phase. The vehicle was configured with a Blueprint Subsea forward-looking sonar, a Norbit multibeam echosounder, and an optical camera system developed in-house by IQUA.
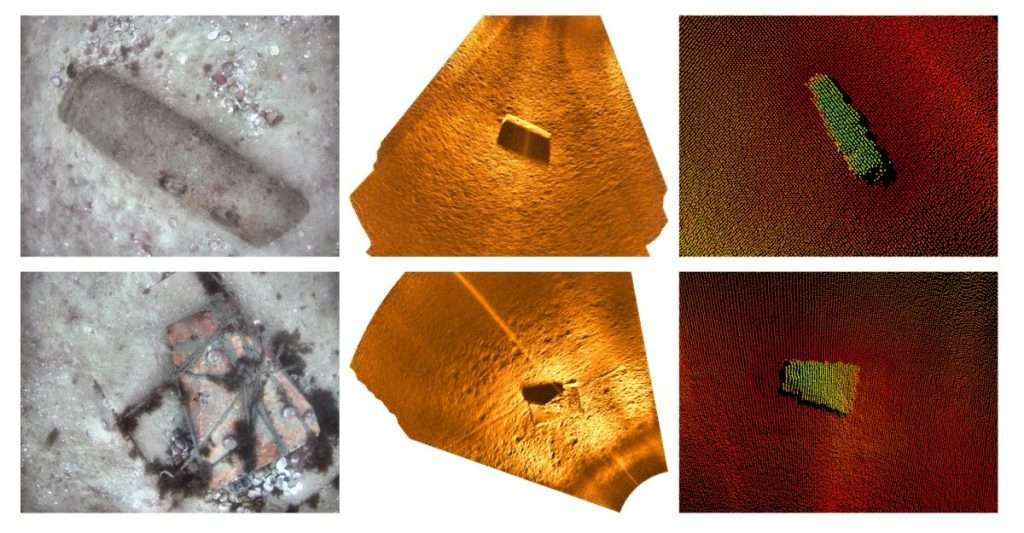
At the core of IQUA’s participation was the MCM pipeline, which combines detection and identification in a single autonomous mission. The vehicle is programmed to follow a search pattern, automatically detect contacts in the forward-looking sonar imagery, replan in real time to inspect each one with sonar, multibeam, and camera, and then resume its initial search pattern.
This year’s main novelty was a new AI-based detector for the sonar imagery, which produced far fewer false positives than the detector used in previous editions. Moreover, during each contact inspection, an AI classifier labeled the contact as mine or non-mine from the optical images, correctly identifying every mine deployed for the exercise, and reporting the result in real time through the acoustic link. When the vehicle surfaced, the camera images, high-frequency sonar images, and multibeam point clouds gathered during each inspection were immediately available for operators to identify every object, along with a semi-automatically generated APP-11 report of the findings.
IQUA also took the opportunity to take part in SPYTE (Sonar PY-curve Test), a test organized by the Swedish Armed Forces to evaluate detection and classification probability. As a result, the company obtained the probability-of-detection curve of the forward-looking sonar, a key input for assessing risk in MCM operations.
Together with the US Navy’s CTG 68.3, IQUA successfully demonstrated STANAG 4817 Vol. 3 interoperability. A US REMUS vehicle searched two of the designated MCM exercise areas with side-scan sonar and sent identification tasks to the SPARUS control station using STANAG 4817 messages. For each identification task received, the control station automatically generated a reacquisition mission, and the vehicle reacquired every contact in under 10 minutes, confirming its nature with optical imagery while the REMUS continued surveying. The time saved, compared with carrying out detection and identification as two separate phases, points to the future of collaborative missions and the importance of system interoperability.
In IQUA’s first collaboration with the REA group, SPARUS mapped the port of Sesimbra and an area crossed by a communications cable. In single missions it produced bathymetry, acoustic maps, and optical mosaics, processed quickly with QPS Qimera and IQUA’s in-house SoundTiles and OpticTiles software. The results showcased the vehicle’s capability for multimodal data gathering and rapid product generation, which is key to the automated assessment of critical infrastructure.
Throughout the exercise, IQUA supported the Spanish Navy’s MCM group, which operates two SPARUS II units, and joined them in the tactical phase to identify contacts in assigned areas. The team also welcomed observers on board during some of their serials and engaged with representatives from other navies and companies. In addition, IQUA collaborated with other industry partners, processing their forward-looking sonar data with its SoundTiles software to produce acoustic maps.