Hosted by the IEEE Oceanic Engineering Society (OES) every two years, this symposium brings the marine robotics community together to share ideas and foster future research and collaboration. The conference focuses on autonomous underwater vehicles (AUVs), autonomous surface vessels (ASVs), underwater gliders, and Lagrangian floats. MBARI is a global leader in developing autonomous technologies to scale observations of marine ecosystems and provide ocean health data urgently needed to inform decision-making about the future of marine life and resources.
Held in Southampton, England, September 1–3, AUV2026 explored all aspects of developing autonomous robots for science and industrial applications, including vehicle design, navigation and sensing, control and operations, and communication and data management.
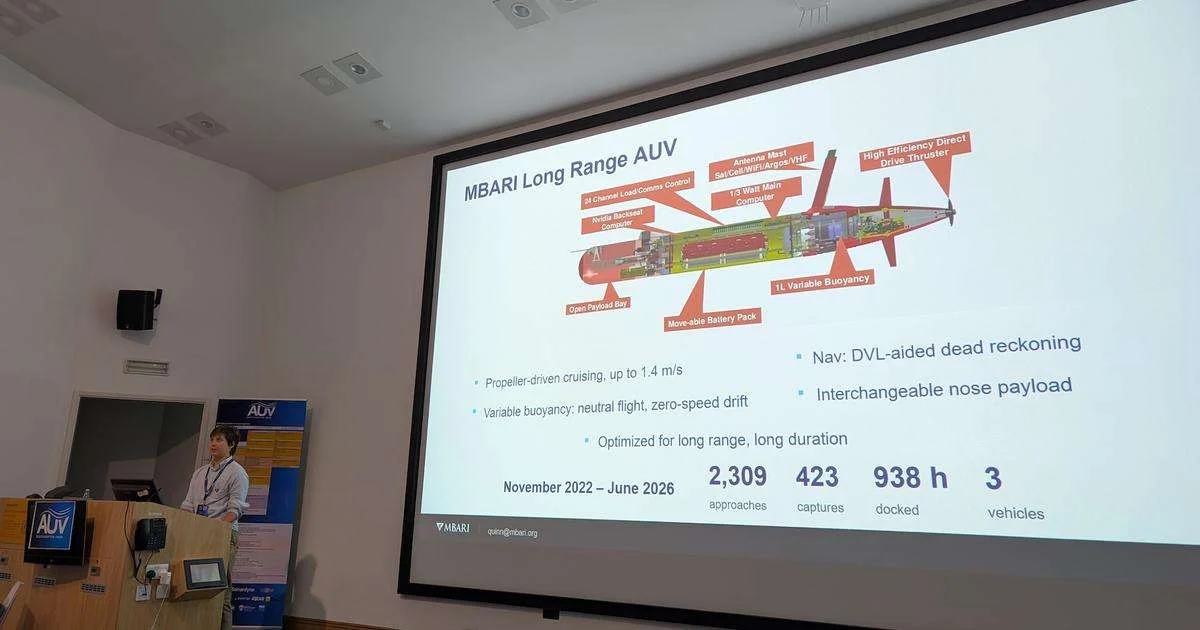
Principal Engineer Giancarlo Troni and Research Engineer Sebastián Rodríguez shared new work developing control and sensor systems for the CoMPAS Lab’s agile MOLA AUV, while Software Engineer Quinn Shemet presented field results from an acoustic docking system for MBARI’s nimble LRAUV.
Together, these efforts showcase how MBARI engineers are taking new approaches in learning-based control and autonomous vehicle design from the lab into the ocean, developing practical technologies that can make underwater exploration more capable, efficient, and scalable.