In a real-life scenario, this capability would enable autonomous systems to continue navigating when satellite navigation has been lost or deliberately denied, supporting mission completion and the safe recovery of valuable assets.
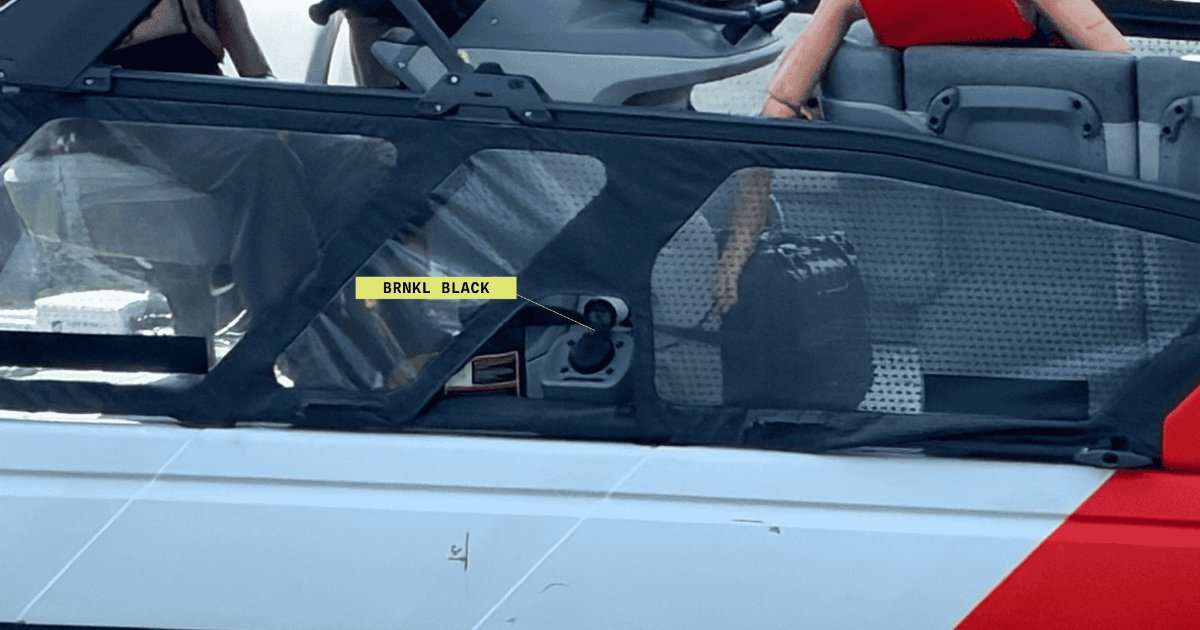
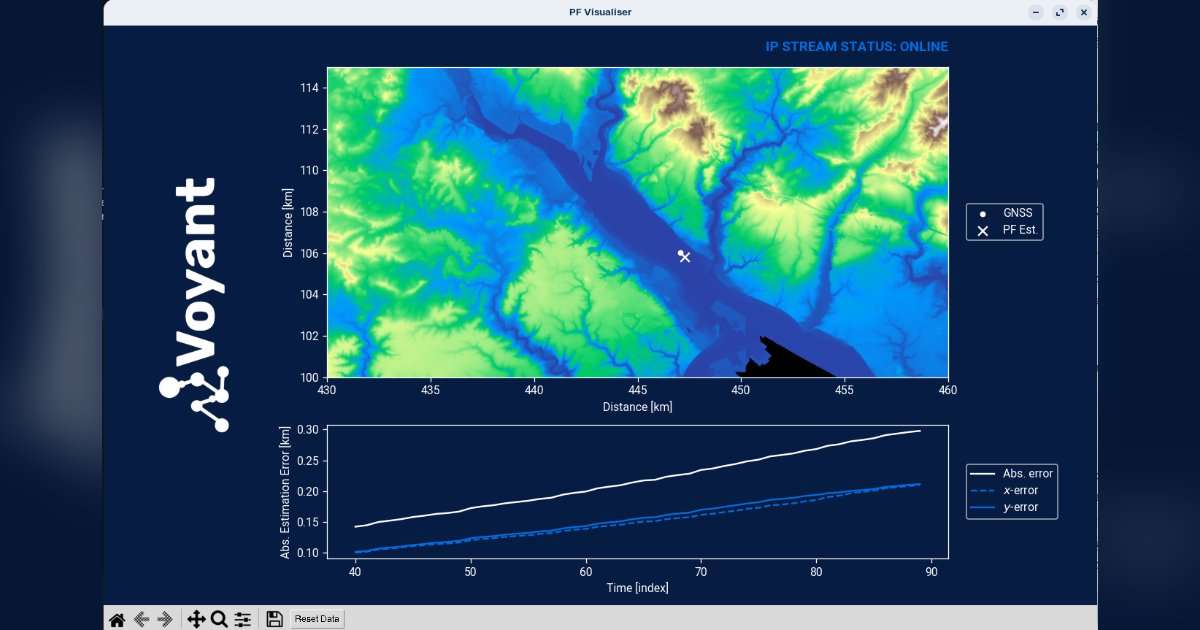
The demonstration took place aboard a Kraken K3 Scout autonomous surface vessel in the demanding littoral waters of the Solent. Operating in real time, Voyant’s software used advanced particle filter algorithms to compare live radar imagery with pre-existing reference maps of the terrain to enable the vessel to determine its position without relying on Global Navigation Satellite Systems (GNSS).
The trial forms part of a wider MOD initiative to explore resilient technologies capable of supporting military operations in contested and congested GNSS-denied environments.
James Norwood, CEO of Voyant, said: “Reliable navigation is fundamental to maritime operations, yet we are entering an era where access to GNSS can no longer be assumed. Working alongside Kraken and the Ministry of Defence, we have demonstrated a practical capability that supports the safe and effective deployment of autonomous maritime systems in challenging operational conditions.
“The demonstration represents another milestone in the UK’s continued investment in sovereign technologies that strengthen resilience, enhance operational freedom and support the next generation of autonomous defense capabilities.”
Modern military operations depend heavily on GNSS, including GPS, to provide PNT information for ships, aircraft, vehicles, missiles, and autonomous platforms. However, satellite signals are increasingly vulnerable to jamming, spoofing, and disruption, making resilient alternatives an increasingly important operational requirement.
The challenge is particularly acute in the littoral environment, where coastlines, changing terrain, and dense infrastructure can naturally reduce satellite reception—even before adversaries actively seek to deny it. Maintaining accurate navigation in these complex environments is essential to ensuring autonomous and crewed platforms can continue to operate safely, effectively, and with confidence.
Voyant’s software addresses this challenge by fusing radar data with advanced probabilistic algorithms to estimate a vessel’s position relative to its surroundings and provide an estimate of the uncertainty that is attributed to this estimate. Rather than relying on satellite signals, the system continually matches real-time sensor observations against known geographic features, providing trustworthy and resilient navigation even when GNSS is unavailable.
As autonomous maritime systems become increasingly important across defense and security applications, technologies that enable safe and reliable operation in contested environments will be critical.